rm_common::TrackerResetServiceCaller Class Reference
#include <service_caller.h>
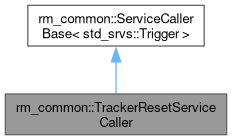
Inheritance diagram for rm_common::TrackerResetServiceCaller:
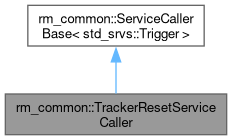
Collaboration diagram for rm_common::TrackerResetServiceCaller:
Public Member Functions | |
| TrackerResetServiceCaller (ros::NodeHandle &nh) | |
| void | reset () |
 Public Member Functions inherited from rm_common::ServiceCallerBase< std_srvs::Trigger > | |
| ServiceCallerBase (ros::NodeHandle &nh, const std::string &service_name="") | |
| ServiceCallerBase (ros::NodeHandle &nh, std::string &service_name) | |
| ServiceCallerBase (XmlRpc::XmlRpcValue &controllers, ros::NodeHandle &nh, const std::string &service_name="") | |
| ~ServiceCallerBase () | |
| void | callService () |
| std_srvs::Trigger & | getService () |
| bool | isCalling () |
Additional Inherited Members | |
| Protected Member Functions inherited from rm_common::ServiceCallerBase< std_srvs::Trigger > | |
| void | callingThread () |
| Protected Attributes inherited from rm_common::ServiceCallerBase< std_srvs::Trigger > | |
| std::string | service_name_ |
| ros::ServiceClient | client_ |
| std_srvs::Trigger | service_ |
| std::thread * | thread_ |
| std::mutex | mutex_ |
| int | fail_count_ |
| int | fail_limit_ |
Constructor & Destructor Documentation
◆ TrackerResetServiceCaller()
|
inlineexplicit |
Member Function Documentation
◆ reset()
|
inline |
The documentation for this class was generated from the following file:
- rm_common/include/rm_common/decision/service_caller.h
Generated by
 1.12.0