service_caller.h File Reference
#include <chrono>#include <mutex>#include <thread>#include <utility>#include <ros/ros.h>#include <ros/service.h>#include <controller_manager_msgs/SwitchController.h>#include <control_msgs/QueryCalibrationState.h>#include <rm_msgs/StatusChange.h>#include <std_srvs/Empty.h>#include <std_srvs/SetBool.h>#include <std_srvs/Trigger.h>
Include dependency graph for service_caller.h:

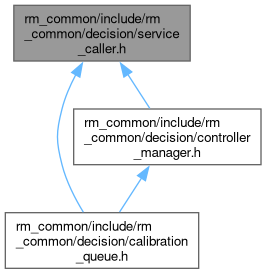
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Namespaces | |
| namespace | rm_common |
Generated by
 1.12.0